Note 1
Vectors and Vector Spaces
If you have backgrounds on physics or computer science, you are probably familiar with what vectors are. In physics classes, we learn that vectors are quantities with magnitude and direction. In computer science, vectors are introduced as lists or arrays of data. Both definitions capture different aspects of what vectors are. Throughout the notes, we will implement both understandings. In this note, we will discuss fundamental terms for vectors and vector spaces before implementing matrices in vector spaces. Also, most of the heavy abstractions are done in modern algebra, so it will be an introduction.
1.1 Basic Terms and Notations
First, let’s get started by building from common notations and definitions.
Definition 1.1.1
\(\mathbb {R}\) and \(\mathbb {C}\) denote the set of real and complex numbers respectively. Epsilon symbols \(\in \) and \(\notin \) are used to denote whether an element is in the set or not.
Examples of using such notations would be \(\pi \in \mathbb {C}\) and \(i \notin \mathbb {R}\).
Definition 1.1.2
A vector space \(\mathbb {V}\) is a set of elements and scalars with addition properties and scalar multiplication that adheres to the following ten properties, or axioms for a vector space. Moreover, the elements of \(\mathbb {V}\) are known as vectors.
- Vector Addition
- A1.
- Closure: \(\forall \, u, v \in \mathbb {V}\), \(u \oplus v \in \mathbb {V}\).
- A2.
- Commutativity: \(\forall \, u, v \in \mathbb {V}\), \(u \oplus v = v \oplus u\).
- A3.
- Associativity: \(\forall \, u, v, w \in \mathbb {V}\), \(u \oplus (v \oplus w) = (u \oplus v) \oplus w\).
- A4.
- Additive Identity Element: \(\exists \, 0 \in \mathbb {V}\) such that \(\forall \, u \in \mathbb {V}, u \oplus 0 = u\), also known as the zero vector.
- A5.
- Additive Inverses: \(\forall \, u \in \mathbb {V}, \exists \, -u \in \mathbb {V}\) such that \(u \oplus (-u) = 0\).
- Scalar Multiplication
- S1.
- Closure: \(\forall \, u \in \mathbb {V}\) and scalars \(\alpha \), \(\alpha \odot u \in \mathbb {V}\).
- S2.
- Associativity: \(\forall \, u \in \mathbb {V}\) and scalars \(\alpha , \beta \), \(\alpha \odot (\beta \odot u) = (\alpha \cdot \beta ) \odot u\).
- S3.
- Identity Element: \(\forall \, u \in \mathbb {V}\), \(1 \odot u = u\).
- S4.
- Distributivity I: \(\forall \, u \in \mathbb {V}\) and scalars \(\alpha , \beta \), \((\alpha + \beta ) \odot u = \alpha \odot u \oplus \beta \odot u\).
- S5.
- Distributivity II: \(\forall \, u, v \in \mathbb {V}\) and scalars \(\alpha \), \(\alpha \odot (u \oplus v) = \alpha \odot u \oplus \alpha \odot v\).
Side note here is that for this section of the note, we will be using the binary operation symbols \(\oplus \) and \(\odot \) to denote vector addition and scalar multiplication. However, from the next section, we will be using more standard notations like \(v + u\) and \(\lambda v\) for vector addition and scalar multiplication. The reason I decided to use this is that this is the way I first learned and it helped me to emphasize axioms for vector spaces.
Definition 1.1.3
An \(n\)-tuple is an ordered array, or list, of \(n\) real numbers. For an \(n\)-tuple, its dimension is said to be \(n\)-dimensional and the set of such real tuples is \(n\)-space, denoted as \(\mathbb {R}^n\).
For instance, the following \(4\)-tuple is in \(4\)-space. \[ \begin {bmatrix} 1 & 2 & 3 & 4 \end {bmatrix} \in \mathbb {R}^4 \] With tuples in mind, let’s take a look at how we can represent \(2\)-tuples, \(3\)-tuples, and vectors in \(\mathbb {R}^2\) and \(\mathbb {R}^3\). The vector space \(\mathbb {R}^2\) can simply be conceived as \(2\)-dimensional space, or plane. Also, in linear algebra, we generally don’t move the tail of a vector from the origin as we do in introductory physics classes.
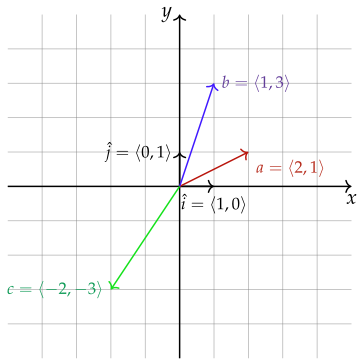
From the graph above, there are two vectors \(\hat {i}\) and \(\hat {j}\). They are called “\(i\) hat” and “\(j\) hat” respectively.
Definition 1.1.4
Unit Vectors are vectors with magnitude \(1\) that are used to specify direction.
Here, \(\hat {i}\) and \(\hat {j}\) denote the unit vectors, and they are the standard symbol. If you wondered if unit vectors are used to construct vectors, you are right! In our examples above, we can write each vector as the following. \begin{align*} a &= \langle 2, 1 \rangle = 2 \hat {i} + \hat {j} \\ b &= \langle 1, 3 \rangle = 1 \hat {i} + 3 \hat {j} \\ c &= \langle -2, -3 \rangle = -2 \hat {i} - 3 \hat {j} \end{align*}
Now, let’s take a look at vector space \(\mathbb {R}^3\). There are two ways of graphing \(3\)-dimensional space: right-handed system and left-handed system. However, we will be using right-hand system throughout the notes.
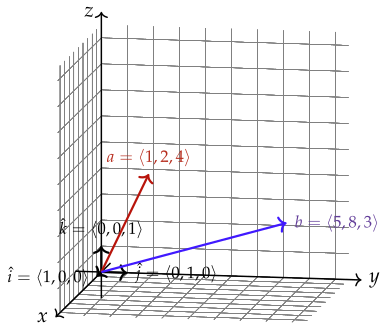
Here, \(\hat {i}\), \(\hat {j}\), and \(\hat {k}\) are the unit vectors. Going back to the definition of vector spaces, we can write the following equations for \(u = \langle x_1, y_1, z_1 \rangle , v = \langle x_2, y_2, z_2 \rangle \in \mathbb {R}^3\) and \(\alpha \in \mathbb {R}\). \begin{align*} u \oplus v &= \langle x_1, y_1, z_1 \rangle + \langle x_2, y_2, z_2 \rangle = \langle x_1 + x_2, y_1 + y_2, z_1 + z_2 \rangle \\ \alpha \odot u &= \alpha \odot \langle x_1, y_1, z_1 \rangle = \langle \alpha x_1, \alpha y_1, \alpha z_1 \rangle \end{align*}
Continuing, we can also distinguish vector spaces with different scalars with the following terms.
Definition 1.1.5
If the set of scalars is in \(\mathbb {R}\), then the vector space is known as a vector space over \(\mathbb {R}\), or a real vector space. Similarly, if the scalars are in \(\mathbb {C}\), then the vector space is denoted as a vector space over \(\mathbb {C}\), or a complex vector space.
One thing to note is that there is a concept called scalar fields; however, we will not go too deep into such fields. Before we move on to different concepts in vector spaces, I wanted to discuss about tuples and dimensions.
Now that we saw some geometrical interpretation of vector spaces, let’s discuss more information with some problems.